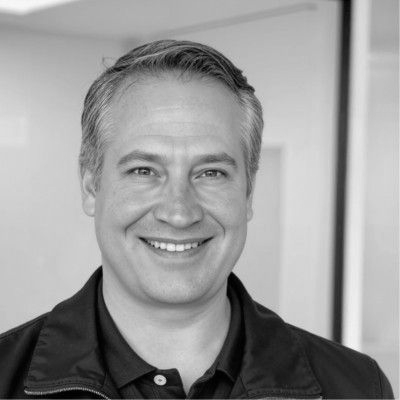
Marc Holzäpfel has spent 18 years bringing automated driving from research into series production. At Porsche, he delivered InnoDrive, a predictive driver assistance system, to market. At CARIAD, he led the Automated Driving Alliance with Bosch: a program of more than 1,200 engineers serving multiple Volkswagen Group brands. There he drove the shift to an AI-first architecture and built the cross-company governance that turned unpredictable releases into a fast, reliable cadence. Today, as an independent Engineering Advisor, he helps technology companies build engineering ecosystems for complex cyber-physical products.
ENVITED Community Meeting
From SDV to AIDV: Enabling Smart Vehicles Through Data-Driven Engineering
3 November 2026 | Munich (House of Communication)
Pre-Event of the ASAM International Conference
Software- and AI-defined mobility are reshaping how complex vehicle systems are designed, validated, and operated. Functionality is increasingly software- and AI-driven, continuously evolving over the lifecycle, shifting focus from hardware toward software, data, and continuous validation. This shift spans multiple domains beyond ADAS and automated driving, including energy management, powertrain optimization, predictive maintenance, and user-facing digital systems.
A key challenge is validating end-to-end and hybrid architectures. Modern systems combine classical modular software with AI-based components, as well as end-to-end approaches where behavior is learned from data. These paradigms challenge traditional validation, as system behavior emerges from complex interactions rather than deterministic logic. New strategies are required, covering component-level verification, system integration, full-system behavior in dynamic scenarios, and continuous validation under OTA updates.
Data-driven Engineering and Simulation play a central role - not only for development and testing, but as a foundation for scalable validation and structured evidence generation across the lifecycle. This increases the importance of simulation credibility, including transparency, traceability, and reliability.
The ENVITED Community Meeting, organized by the ASCS Association, brings together industry and academic experts to address these challenges. As a pre-event to the ASAM International Conference, it connects methodological innovation, industrial application, and standardization across software-defined vehicle systems.
AGENDA
3 November 2026
10:15 AM CET
Registration
Networking and Warm-up
10:45 AM
Welcome & Introduction
Alexander F. Walser | Automotive Solution Center for Simulation e.V.
10:50 AM
Keynote
Marc Holzäpfel |
Holzäpfel Engineering Advisory
11:20 AM
From GIS Data to ASAM-Compliant 3D Environments for ADAS/AV Simulation
Mirco NIERENZ | TrianGraphics GmbH
Abstract
AI-driven vehicle development requires large amounts of reliable scenario data. While dynamic traffic is widely addressed, the automated creation of simulation-ready static environments - road networks, terrain and infrastructure - remains challenging. GIS and navigation data often contain topology errors, missing elevation information, unclear lane assignments and incompatible coordinate systems.
This presentation introduces a modular pipeline that transforms heterogeneous geospatial data into structured road networks, ASAM OpenDRIVE files and optimized 3D meshes. Preprocessing, normalization and semantic enrichment improve source data quality. The script-based workflow can run on premises or in the cloud using Docker containers, enabling reproducible generation at scale.
A central topic is the gap between formal standard compliance and actual usability in simulation. Within the Gaia-X 4 PLC-AAD project, TrianGraphics developed open-source tools under the OpenMSL framework to add metadata to OpenDRIVE and OpenSCENARIO assets, search large data collections and validate generated content. In addition to syntactic checks with the ASAM Quality Checker, further validation bundles detect semantic and functional problems that may cause runtime errors.
The presentation summarizes practical lessons learned and proposes clearer specifications, better metadata requirements and validation levels that reflect simulator-specific needs.
11:40 AM
Quantifying Simulation Quality for Virtual Homologation
Basit KAHN| AAI Innovations GmbH
Abstract
As vehicles become software and AI defined, physical testing alone can no longer cover the scenario space needed for safe approval. Regulations such as UN R157, the EU ADS Regulation (EU) 2022/1426 and the UNECE NATM framework increasingly accept simulation as evidence. However, a virtual test result is only as trustworthy as the toolchain behind it: the scenario, the environment and map data, the sensor and vehicle models, and the simulation framework itself.
Today, simulation quality is described in many different, mostly non comparable ways. Credibility assessments are often manual, tool specific and hard to exchange between OEMs, suppliers, technical services and authorities.
This talk presents the approach of the ASAM QSQ (Quantifying Simulation Quality) project. QSQ works towards industry consensus on how simulation quality is defined, measured and communicated, and towards a standardized, machine readable format for storing and exchanging quality metrics. Key messages:
1. Virtual homologation needs measurable, not only documented, simulation quality.
2. Quality metrics must cover the whole toolchain, from HD maps and 3D environments to models and frameworks, and must be traceable across the ASAM OpenX ecosystem.
3. A shared, machine readable metrics format makes credibility evidence comparable and reusable, and allows quality checks to run continuously in CI/CD and OTA driven development.
4. Pre-competitive cooperation is required to turn this into accepted practice between industry, technical services and regulators.
The talk closes with the current status of QSQ, open questions, and how the community can contribute.
12:00 noon
From Requirements to Continuous Homologation:
Agentic AI for ODD Aware ADAS & Autonomous Driving Validation.
Stephen LERNOUT | Deontic
Abstract
ADAS and autonomous driving systems must be validated across an exploding number of requirements, Operational Design Domains, geographic regions, and edge cases. Yet much of today’s scenario-based validation workflow remains manual. Engineers translate requirements into test scenarios, construct road networks, adapt scenarios to new ODDs and repeat the process whenever regulations, standards or system requirements change. As autonomy scales, this approach becomes increasingly difficult to sustain. This presentation introduces an agentic AI approach to turning requirements and ODD definitions directly into standards compliant simulation scenarios, creating the foundation for a more automated and ultimately continuous homologation workflow.
Deontic uses generative AI agents to interpret natural language requirements and automatically generate and validate the corresponding road networks, scenes, OpenDRIVE and OpenSCENARIO assets. ASAM standards provide the interoperability layer connecting generated scenarios with existing simulation and validation environments. The approach extends beyond individual scenario generation by making the ODD a first class component of validation. Using structured ODD models based on ISO 34503 and ASAM OpenODD, scenarios can be generated within an ODD, at its boundaries and across relevant combinations of road infrastructure, speed, environmental conditions and geographic constraints. This enables engineering teams to systematically improve scenario diversity and ODD coverage rather than simply increasing scenario volume.
The presentation also outlines the path toward continuous homologation. Regulatory and standards changes can be monitored automatically, allowing an AI agent to identify which validation requirements, scenarios or scenario libraries need to be updated. In the next stage, results from simulation environments can flow back into the validation process, creating traceable links between requirements, ODDs, scenarios, simulation outcomes and homologation evidence.
Finally, we explore how this validation intelligence layer can connect with emerging world models and Vision Language Action systems, using structured scenarios not only to generate simulation assets but also to evaluate increasingly complex autonomous driving AI.
The result is a shift from manual scenario engineering toward an ODD aware, standards based and continuously evolving validation pipeline, enabling autonomy teams to scale validation as quickly as their systems, markets and regulatory environments evolve.
12:20 PM
Lunch Break
1:20 PM
Re-Engineering Automotive Development with Virtualization and AI
Shift-left through virtual first - from System to Silicon
N.N. | ANSYS part of Synopsis
Abstract
Automotive development is entering a new era where increasing system complexity, software-defined architectures, and faster innovation cycles demand a fundamental rethink of traditional engineering. This presentation explores how a virtual-first, AI-enabled development approach can shift engineering left, connecting system-level decisions with software and silicon much earlier in the development lifecycle. By combining virtualization, simulation, and AI across the System-to-Silicon continuum, engineering teams can evaluate architectures earlier, accelerate development and validation, and reduce dependency on physical prototypes. The result is a more integrated, agile development model built for the complexity of next-generation vehicles.
1:40 PM
Scalable SDV Validation & Data Strategy: Bridging Cloud-Native SiL, Modular HiL and E2E Fleet
Testing through an Open AI-Driven Ecosystem
Guillaume OBDAM | AKKODIS Germany Consulting GmbH
Abstract
Summary
The transition to Software-Defined Vehicles (SDV) has rendered traditional, sequential V-Model validation cycles as a bottleneck for DevOps-driven CI/CD. Currently, the automotive industry faces a fragmented landscape where development, validation, production, and aftersales operate in technical silos.
This is further complicated by complex standards that often function as vague frameworks rather than concrete bases for validation. Consequently, validation tools are frequently retroactively adapted to specific implementations rather than addressing deviations from core requirements. As OEMs move away from universal standards, the industry is left with unclear requirements and a proliferation of customer-specific, error-prone tool adaptations. These inconsistent IT architectures result in data being collected but only superficially evaluated, while valuable insights from vehicle fleets remain disconnected from early-stage development. Furthermore, varying global regulations regarding security and data protection necessitate rigorous anonymization, adding another layer of complexity.
This contribution focuses on bridging the gap between development, validation, and pre-launch engineering with real-world performance by focusing on two key pillars:
- Development & Validation Phase: The primary objective is to refine system reliability and performance before market entry. By utilizing advanced simulation and testing frameworks, this approach ensures that products meet stringent safety and functional requirements during the design freeze and SOP (Start of Production) lead-up.
- Early Aftersales Integration: A distinctive "Early Warning" capability integrates data from the first months of field operation to validate development assumptions against real-world stressors. This allows for Rapid Iteration of validation test cases and Data-Driven Calibration of digital twins using field telemetry.
The proposed "kit-of-parts" system integrates commercial validation and data logger tools with open-source components. By strictly adhering to established standards (e.g., Eclipse openMDM®, ASAM ODS, ASAM MDF/OSI, Modelica FMI/FMU, and OSRF ROS2), the system achieves unprecedented environmental parity between virtual SiL and real-time HiL. To address exponential test-space complexity, the framework implements a dual-engine execution strategy: Rule-based Testing to ensure functional safety (ISO 26262) and AI-driven Testing to employ generative scenario modeling for "edge case" discovery and automated anomaly detection.
Ultimately, this approach establishes a coordinated, cross-platform data foundation spanning virtual cloud instances, real-time laboratory setups, and end-to-end vehicle environments - essential for reducing time-to-market while ensuring comprehensive vehicle safety.
Degree of Innovation
The core innovation is a unified data warehouse that collapses traditional silos between development, production, and aftersales. By establishing a cross-platform data foundation - synchronizing with the cloud, the lab, the test vehicle and vehicles using shadow test mode - this framework enables OEMs to accelerate time-to-market while maintaining rigorous, real-time safety validation
Key Topic Assignment
Software-Defined Vehicle (SDV) Validation combined with Data Driven Development & Organizational Transformation. Necessary are Cloud Computing in Automotive, AI-based Testing & Data analysis Methods
2:00 PM
Code Compliance as the Foundation for Trustworthy AI-Defined Vehicle Development
Andreas LAURINGER| Kontrol GmbH
Abstract
As software-defined and AI-defined vehicles continue to increase in complexity, ensuring compliance, traceability, and validation across the complete development lifecycle becomes a critical challenge. At Kontrol, we address this challenge through a code-centric compliance approach that integrates software quality, regulatory requirements, safety expectations, and engineering evidence into a continuous validation framework.
The presentation will demonstrate how code compliance can serve as the backbone for modern vehicle development and validation by connecting development artifacts, simulation results, test evidence, and governance requirements in a single traceable workflow.
The session will cover:
- Simulation for continuous validation and OTA-driven development through automated compliance monitoring and evidence generation.
- Validation of hybrid and end-to-end system architectures with traceable links between requirements, code, models, tests, and deployed software.
- Virtual homologation approaches supported by auditable compliance evidence and digital engineering artifacts.
- Integration of simulation and compliance verification into modern CI/CD pipelines.
- AI-enabled simulation and data-driven testing approaches with transparent governance and validation records.
- Data quality, traceability, and trustworthy simulation supported by end-to-end lineage and compliance controls.
- Interoperability and standardization through alignment with industry standards and ecosystems such as ASAM OpenX.
- Opportunities for pre-competitive collaboration around common compliance, validation, and traceability challenges facing the automotive industry.
- Using practical examples from software-intensive engineering environments, the presentation will show how organizations can reduce compliance effort, improve audit readiness, accelerate development cycles, and build confidence in increasingly autonomous and AI-enabled vehicle systems.
2:20 PM
Missing Edges First: Deterministic Gap Analysis on a Safety Evidence Graph
Arnd HEKERMANS | viprove
Abstract
Software- and AI-defined vehicles produce requirements, scenarios, simulation assets, test runs and ALM links faster than anyone can decide whether the resulting evidence holds together. What stays open is the assessor's question: which required links are missing, which present links do not prove what they claim - and will the same check give the same answer tomorrow? Homologation rarely fails on an artifact somebody produced. It fails on an edge nobody drew - or on an edge that is there, green, and proves nothing.
This talk presents viprove as a typed safety evidence graph with Visualize and Analyze as its core stages - with report and seal as Analyze outputs - plus an owned Execute path only where we run the stack ourselves. Visualize builds the graph: project artifacts - requirements, OpenSCENARIO scenarios, ALM items, tests, runs - ingested as typed nodes and edges against a frozen domain layer. The graph is what makes a missing edge nameable; which edges are required is decided by the grammar, in the next step. Analyze runs a versioned, executable grammar pack over that graph and returns a scoped verdict: findings by type (norm, SYS, test, over-fill, integrity including ASIL, timing by reason, grammar), a report, and a seal. New run evidence — whether from that owned SiL/IT Execute path or from external HiL/CI - is re-ingested and re-analyzed the same way. Report and seal are always outputs of Analyze, not of the run source.
Domain mapping and grammar pack are frozen together, pinned by a domain hash and a grammar version; the seal is a SHA-256 over the canonical report body, excluding only timestamp and seal - so the same graph under the same freeze reproduces the same hash.
Determinism is deliberately scoped. It holds for Analyze against a given freeze: same graph, same grammar version, same counting policy, same seal. LLM assistance is used only to map normative documents into the domain layer, under human review, and never in the verdict. A green result means structural consistency under one grammar pack, not a release and not a homologation statement; an empty domain layer yields zero norm gaps, which is a warning and not compliance; and a seal is a replayable record, not a certificate.
We demonstrate live on an L2 ADAS evidence graph - lane keeping and ACC, hazard to safety goal to SYS.2 to SWE.1 to evidence - where a single sealed Analyze run returns a typed finding inventory (system gaps, integrity, timing by reason, grammar, and related checks). The inventory stays on screen; we walk two of its patterns in depth. First, the ACC longitudinal command path under an ASIL C goal: a system requirement with no software requirement beneath it, and no independent monitor on the same goal. Second, a timing verdict where a HiL PASS and a green verifies link cannot serve its safety goal because the claim target (200 ms) does not match that goal's FTTI (150 ms). Other timing findings remain visible in the same seal - for example a pending run record, or goals with no FTTI reaction evidence yet. We then re-run Analyze on stage and get the identical seal - the "same answer tomorrow" question, answered live. This is a graph over artifacts, not a live simulation run. The demo project was authored with known defects; the grammar pack was not told where they are.
A second, complete Analyze run on a robotics safety stack - different domain pack and integrity model (PL/SIL), using the same Visualize · Analyze path with a sealed result - shows the engine is not automotive-only.
The ENVITED-X integration point - Services and Checks as the process category, a validation report as the output - is presented as a documented design, not a connected dock. We close with two open questions for discussion: how to express confidence in PDF-based norm extraction, and how far gap closing can be automated without leaving the deterministic core.
2:40 PM
Coffee Break
3:20 PM
AI-Enabled Validation of Autonomous Driving Functions in Critical Project Phases
Martin HENNE, Jasmin PUCHALOWITZ | EDAG GmbH
Abstract
The validation and release of autonomous driving functions remain among the most challenging activities in automotive development, particularly during late project stages when homologation, release decisions, and quality targets converge. While modern development environments increasingly leverage simulation and automation, final validation activities still rely heavily on manual testing at vehicle level or on full-system integration test benches. This approach is constrained by limited vehicle availability, labor-intensive test execution, and software tool chains that are often expensive, fragmented, and insufficiently aligned with the speed requirements of contemporary development processes.
At the same time, recent initiatives across automotive OEMs, suppliers, and engineering service providers clearly demonstrate a growing expectation that Artificial Intelligence will become an integral part of the entire validation process. From automated test generation and intelligent scenario selection to AI-supported result analysis and risk-based validation strategies, numerous approaches are emerging. However, despite significant momentum, the industry still lacks broadly established methods, standards, and tool ecosystems that enable scalable and trustworthy AI-driven validation for safety-critical systems.
This presentation provides a practical overview of the current state of AI adoption in the validation of autonomous driving functions, focusing on the challenges and opportunities encountered during critical project phases. Using selected real-world examples, it highlights how AI technologies can increase testing efficiency, improve coverage, accelerate release activities, and reduce dependency on scarce physical test resources. Furthermore, the presentation discusses the benefits already achieved in industrial projects, outlines remaining technical and organizational challenges, and explores the future potential of AI-driven validation workflows for homologation-relevant testing and safety assurance.
By sharing lessons learned, emerging best practices, and concrete application examples, the presentation aims to contribute to the ongoing discussion on how AI can transform the validation landscape for autonomous and software-defined vehicles.
3:40 PM
From Static Approval Evidence to Dynamic Evidence Systems:
Rethinking Virtual Homologation for Software-Defined and AI-Enabled Vehicles
Sabine RÖHRICHT, Udo KAEMPF | MHP Management und IT-Beratung GmbH
Abstract
Software-defined and AI-enabled vehicles are changing how vehicles are developed, validated and regulatorily assured. While type-approval frameworks still focus on vehicle types, systems and components, approval-relevant behaviour is increasingly being shaped by software, AI models, data and configurations that evolve through controlled releases.
This raises a central question: if the legal approval object remains largely unchanged, but the underlying vehicle configuration becomes more dynamic, how must the assurance system supporting approval evolve?
Virtual homologation must therefore evolve from primarily point-in-time evidence generation towards a lifecycle-oriented evidence system. Approval-relevant characteristics need to remain demonstrable across software releases, over-the-air updates, configuration variants and complex system interactions. For AI-enabled functions, this challenge is amplified because behaviour may depend not only on software versions, but also on models, data and operational conditions.
Simulation and virtual testing can provide scalable evidence across variants, scenarios and releases. From a regulatory assurance perspective, however, virtual evidence must not only be credible when generated, but also remain traceable to the relevant requirement, vehicle configuration and approval decision. Its applicability and validity must therefore be assessable when software, AI models or system configurations change.
The lifecycle perspective further intensifies these requirements. Software and AI-enabled functionality can evolve long after start of production. While not every update requires renewed approval, approval-relevant changes require systematic impact assessment, validation and evidence generation. Frameworks such as UN Regulations Nos. 155 and 156, ISO 24089 and ISO/PAS 8800 increasingly reflect this shift towards lifecycle-oriented assurance.
The contribution examines how approval-relevant changes can be identified efficiently, how virtual evidence can be structured and maintained throughout the vehicle lifecycle, and how trust can be established across increasingly digital assurance processes. It outlines key capabilities for future assurance architectures: traceability, change-impact assessment, digital evidence management, integration of simulation credibility information and cross-functional governance across development, validation, homologation, cybersecurity and AI.
Together, these capabilities form the basis for scalable virtual homologation in software-defined and AI-enabled vehicles, balancing innovation speed, safety and regulatory confidence throughout the vehicle lifecycle.
4:00 PM
From Ticket Chaos to Trace Intelligence: Scaling AI-Driven Defect Management
Akhil RAJAGOPAL, Hanno STAGE | MHP Management- und IT-Beratung GmbH
Abstract
Modern software-defined vehicle programmes generate vast numbers of defect tickets and trace logs. Critical engineering decisions are often slowed by manual pre-analysis, fragmented toolchains, and reliance on individual experts. In a typical OEM setting, error management teams handle ~300 new tickets per week, yet up to 40% cannot be analysed immediately due to missing information, causing delays and rework. Engineers manually locate trace files, convert binary logs, search for patterns, and copy findings into downstream systems.
This presentation introduces a data-driven AI approach that automates large parts of this workflow. A scalable pipeline ingests ticket and trace data to verify ticket quality, detect duplicates, generate concise summaries, and perform trace-centric root-cause analysis. The key innovation is the tight integration of ticket management and trace analysis in a single pipeline, enabling consistent, repeatable investigations beyond isolated manual efforts. For trace investigations, the system identifies relevant files from large repositories, converts binary traces into machine-readable form, validates data integrity, applies pattern matching, and produces human-readable diagnostics using a large language model (LLM). It also visualises error occurrences and system state transitions to pinpoint fault contexts. Beyond pattern matching, an LLM-based agent autonomously orchestrates investigations by querying signals, cross-referencing ticket context, and iterating towards root-cause hypotheses without predefined rules.
Impact: The approach improves efficiency and decision-making in SDV development. It streamlines ticket creation and analysis for testers and function owners and enables project engineers to perform deep-dive investigations without expert intervention. In production use, initial results indicate up to an 80% reduction in trace analysis effort per ticket, with improved consistency and accessibility for non-experts. Overall, AI-driven automation turns large-scale validation traces into faster root-cause hypotheses, quicker duplicate detection, and more robust ticket quality management, without relying on proprietary tools or data.
Keypoints:
- AI- and data-driven framework for automating ticket and trace analysis in SDV validation.
- Unified, scalable pipeline for ticket quality checks, duplicate detection, summarisation, and trace-centric investigation.
- End-to-end automated trace processing, including file selection, conversion, validation, and pattern-based analysis.
- LLM-supported summaries and visual analytics to accelerate root-cause hypothesis generation and improve accessibility for non-experts
- Measured operational impact, with improved consistency and up to 80% reduction in trace analysis effort per ticket.
4:20 PM
World Café
5:30 PM
End
SPONSOR
Who Should Attend
The ENVITED Community Meeting is intended for professionals and researchers shaping the future of software- and AI-defined mobility.
Relevant roles include:
- SDV and AI-defined vehicle architects
- Software platform, middleware, and cloud engineers
- DevOps, CI/CD, and OTA update specialists
- Simulation, verification, validation, and virtual homologation experts
- Systems engineering and systems validation experts
- ADAS, automated driving, and AI specialists
- Data engineering and digital engineering experts
- Standardization and interoperability experts
- Researchers and academics
- Innovation managers and project leaders
Participants from OEMs, suppliers, technology companies, tool vendors, research institutes, and standardization organizations are invited to contribute and exchange perspectives on simulation, data-driven engineering, and continuous validation for software- and AI-defined vehicle systems.
Join the ENVITED Community Meeting on 3 November 2026 and continue the conversation at the ASAM International Conference on 4–5 November 2026 - secure your combi ticket and be part of the exchange shaping the future of software- and AI-defined mobility.
LOCATION
House of Communication |
link
by public tranportation:
Friedenstr. 24
81671 Munich, Germany
by car:
August-Everding-Str. 25
81671 Munich, Germany
Showcase Your Technology
at the ENVITED Community Meeting
Would you like to present your cutting-edge technology to our audience of decision makers, technical experts, researchers and connect with potential partners and clients? Our exhibition area on 3 November 2026 offers the ideal platform to showcase your solutions, products, or services to an engaged and forward-thinking crowd.
Whether you’re working on groundbreaking simulation software, advanced AI technologies or intelligent services in the field of mobility simulation, we’re excited to feature your innovation at our event. This is your opportunity to highlight your contributions to the future of mobility.
It’s simple to get involved:
Contact us to discuss the possibilities for securing your exhibition stand. Together, we’ll create a space that puts your technology in the spotlight and fosters collaboration with industry leaders and researchers.
Reach out to us now to join the exhibition!
We look forward to hearing from you and showcasing the future of mobility simulation together.